
Full specification
| Parameter | Value |
|---|---|
| Degrees of freedom | 7 |
| Reach | 892 mm |
| Mass per arm | 4.65 kg |
| Payload | 3 kg |
| Modules | RBV1 R48 / R58 / R68 |
| Control | CANopen / CAN-FD |
| Torque sensor | No |
| Brake | No |
| Backdrive | Yes — movable by hand for station positioning |
Source: Crabnova HRV1 arm datasheet and module configuration sheets. Figures verified November 2026 — confirm the exact variant against the datasheet issued with your order.
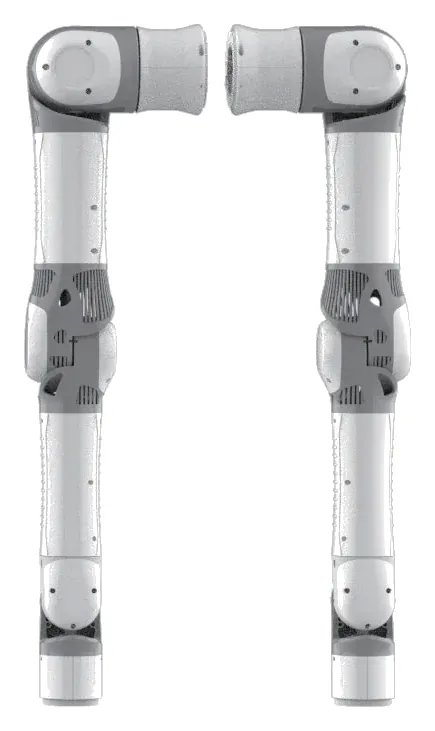
When this is the right choice
- Backdrivable by hand. Position the station, nudge a joint, recover from a collision without a pendant — and record demonstrations without fighting the gear train.
- 4.65 kg per arm is the lightest of the three and 350 g lighter than the force-control version.
- 892 mm reach with a 3 kg payload covers table-top manipulation and most bimanual capture rigs.
- Cheapest per axis — no torque sensor, no brake, which is exactly where the cost of a force-control arm comes from.
When it is the wrong choice
- No brake, so it drops. A vertical arm with power off falls; on a capture station that is usually acceptable because a human is present, but it is not acceptable on a deployed robot.
- No torque sensing. You cannot measure contact force during capture — if the dataset needs force labels, this is the wrong version.
- 3 kg payload. A heavy end effector plus an object will exceed it quickly.
Alternatives at a similar level
- Crabnova HRV1 3 kg force-control — Same reach, torque sensor and brake on every axis
- Crabnova HRV1 15 kg force-control — 15 kg payload, 950 mm reach
- Linker Arm P7 — Lighter arm if you only need to carry a hand
Quote this model
Model, quantity and destination is enough to start — we come back with price, availability and the datasheet.
Crabnova HRV1 3 kg data-collection FAQ
Why would I buy the version without sensors?
Because for pure demonstration capture the human is the sensor. You record joint positions and camera frames; force labels come later from a force-control arm or from the task setup. It is roughly a third cheaper per axis than the force-control build.
Can I add brakes later?
Not as a field retrofit — the brake is inside the joint module. If a deployed robot is the end goal, buy the force-control version now.
How long does it take to ship?
Assembled to order from RBV1 modules; the quotation carries the date for the configuration.
Back to Crabnova (Juxiedrive) · arms & robot platforms · need a model that is not listed?