HRV1 7-DOF arms — three versions
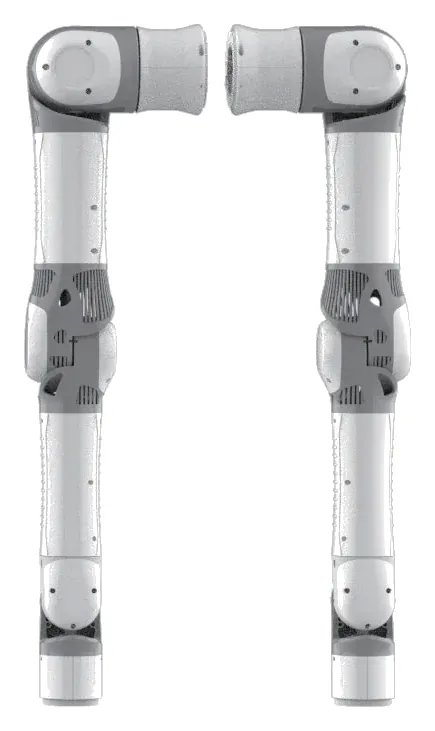
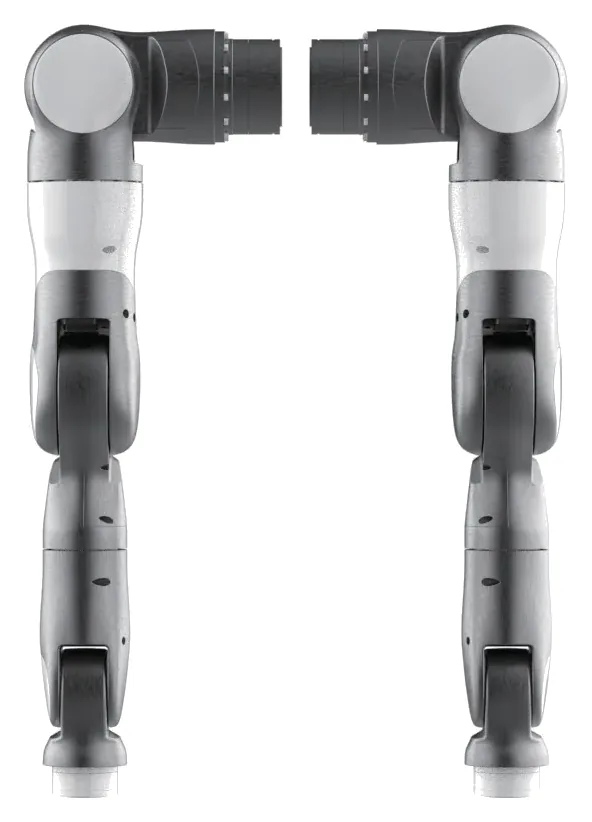
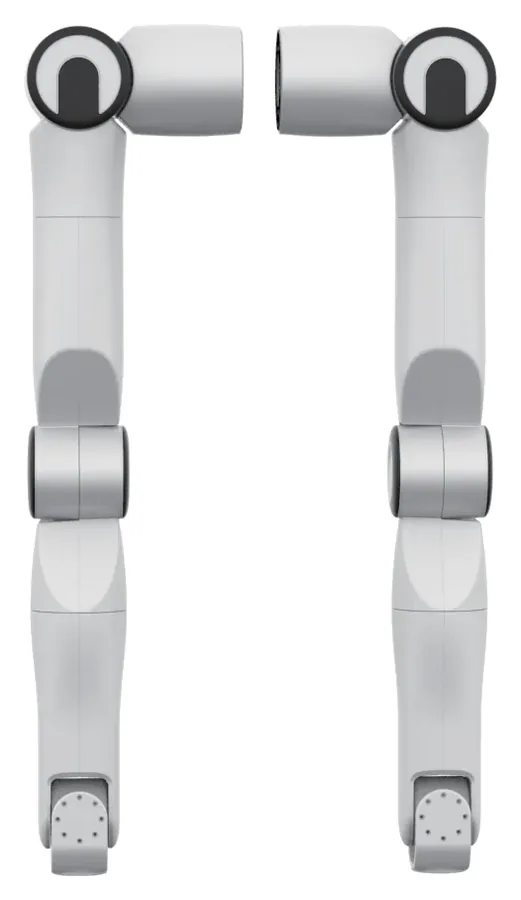
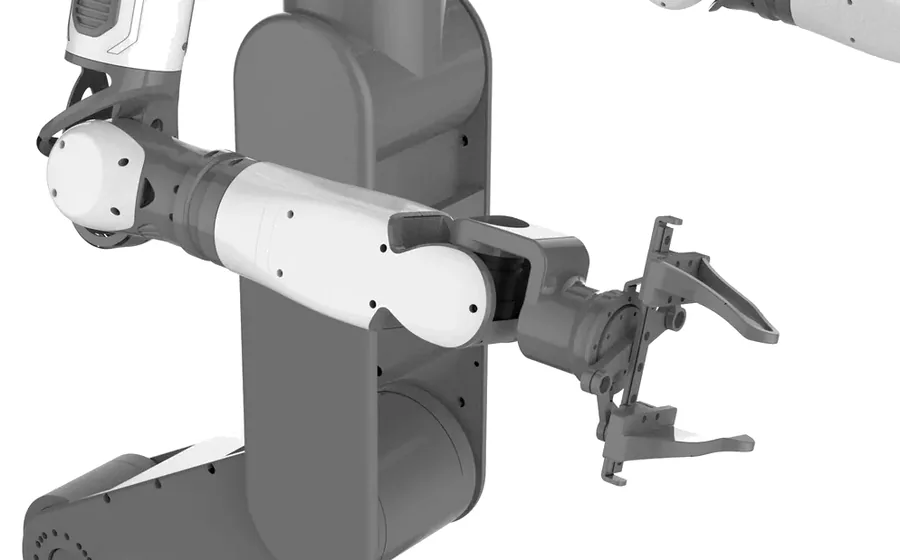
Complete arms assembled from the same joint family we sell as modules. Every axis on the force-control versions carries a torque sensor and a power-off brake; the data-collection version trades those for lower cost per axis.
| Version | Reach | Weight (per arm) | Payload | Control | Modules | Torque sensor | Brakes |
|---|---|---|---|---|---|---|---|
| 3 kg data-collection | 892 mm | 4.65 kg | 3 kg | CANopen / CAN-FD | RBV1 R48/R58/R68 | No | No |
| 3 kg force-control | 892 mm | 5 kg | 3 kg | CANopen / CAN-FD / EtherCAT | RBV3 R48/R58/R68 | Yes | Yes |
| 15 kg force-control | 950 mm | 20 kg | 15 kg | CANopen / CAN-FD / EtherCAT | RBV3 R83/R102/R120 | Yes | Yes |
Specs quoted from manufacturer datasheets; final figures confirmed at quotation.
Wheeled embodied robots — A0 / A1 / A2
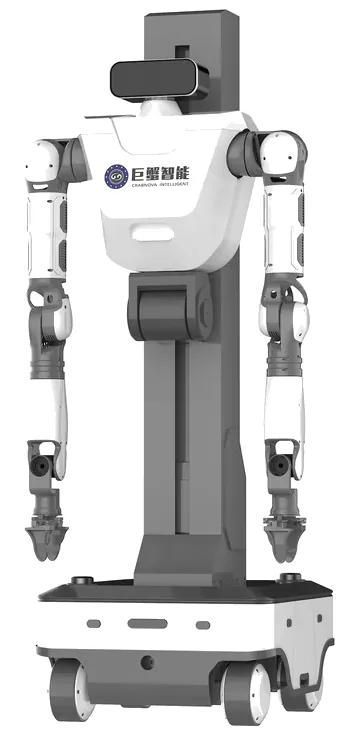
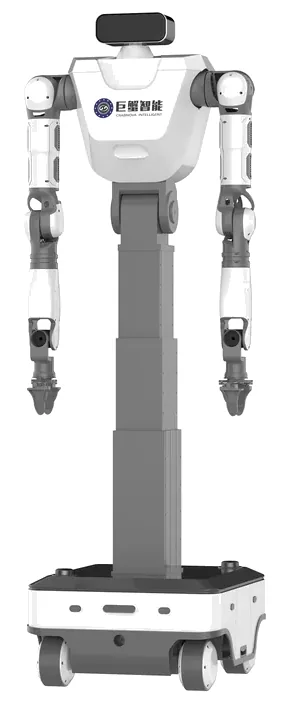
Three wheeled humanoid configurations for lab and light-industrial tasks. A0 and A1 lift the torso on a column; A2 folds for transport and adds two RBV1 waist modules for whole-body motion. All three ship with two R48-Gri grippers.
| Model | Dimensions (mm) | Weight | DOF | Grippers | Module configuration |
|---|---|---|---|---|---|
| A0 lifting wheeled | approx. 1640 × 550 × 600 | 110 kg | 27 | R48-Gri × 2 | Head R48-Lite × 2 · arms R48-Lite × 3, R58-Lite × 2, R68-Lite × 2 · base R80 × 4 |
| A1 lifting wheeled | approx. 1855 × 550 × 600 | 100 kg | 27 | R48-Gri × 2 | Head R48-Lite × 2 · arms R48-Lite × 3, R58-Lite × 2, R68-Lite × 2 · base R80 × 4 |
| A2 folding wheeled | approx. 1791 × 550 × 600 | 120 kg | 30 | R48-Gri × 2 | Head R48-Lite × 2 · arms R48-Lite × 3, R58-Lite × 2, R68-Lite × 2 · waist RBV1 R120-FBN × 2, R102-FBN × 2 · base R80 × 4 |
Specs quoted from manufacturer datasheets; final figures confirmed at quotation.
Platforms beyond the catalogue
The same module family also powers a dual-arm upper-body torso and a foldable lower-limb configuration for embodied-AI research builds. These are quoted as custom configurations — module counts, waist setup and end effectors are all adjustable. See the full joint module line →
FAQ
Do the 7-DOF arms share parts with the joint modules?
Yes. The arms are assembled from the same RBV1 / RBV3 joint modules listed on our joint module pages, so spare modules and firmware tooling carry over.
Which arm version fits teleoperation data collection?
The 3 kg data-collection version: RBV1 modules without torque sensors or brakes, CANopen or CAN-FD control, and the lowest cost per axis. For force-control demos choose the RBV3 versions.
Can the wheeled robots be configured differently?
Yes — module counts, waist configuration and grippers are configurable. A0 and A1 use a lifting column, A2 folds for transport and adds two RBV1 waist modules. Tell us the task and we quote the configuration.
What is the lead time for arms and platforms?
Factory orders are typically 4 to 6 weeks, dispatched worldwide with tracked express. Sample stock in California covers the joint modules; arms and platforms ship direct from the factory.