
Full specification
| Parameter | Value |
|---|---|
| Sensors | 15 |
| Capture accuracy | 0.1° |
| Encoder type | Magnetic — mechanical angle, not integrated rate |
| Weight | 190 g per glove |
| Wireless | ESP-NOW · 20–30 Hz |
| Latency | under 10 ms |
| Battery | 500 mAh · about 3.2 h |
| Charging | USB Type-C |
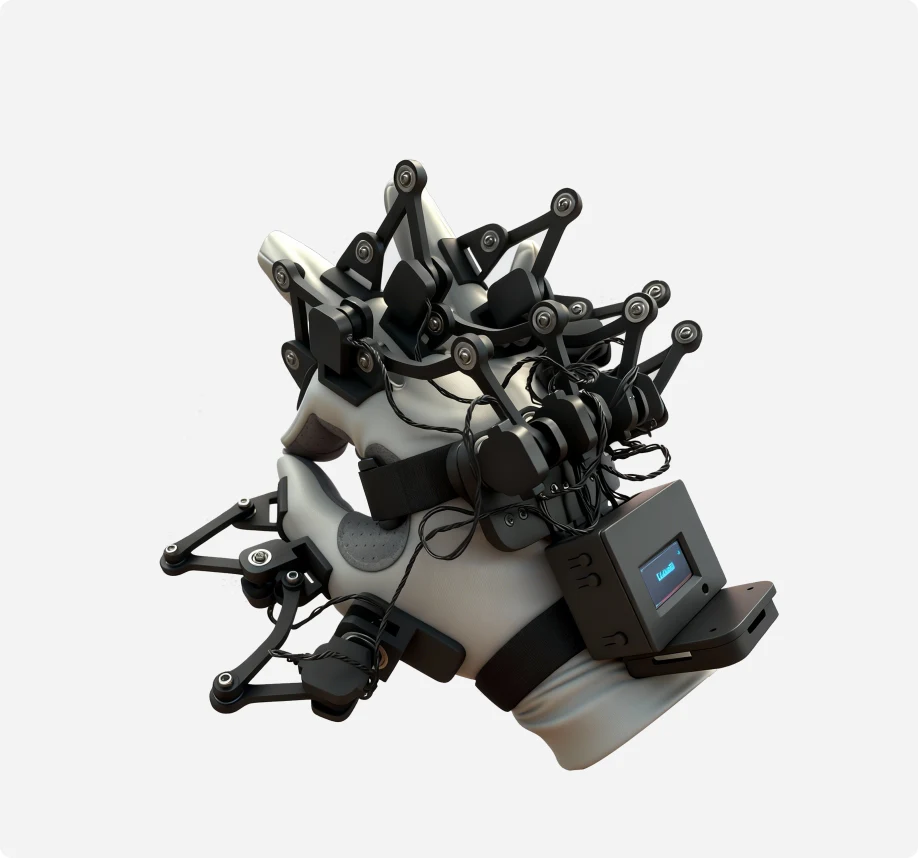
| Structure | Rigid exoskeleton linkage alongside each finger |
| SDK | Same ecosystem, SDK and ROS packages as the Linker Hand range |
Source: Linker EG (LEG1-02) product manual and the Linker glove range documentation. Figures verified November 2026 — confirm the exact variant against the datasheet issued with your order.
When this is the right choice
- No drift over a session. Angle is measured by a magnetic encoder on a mechanical linkage, so there is nothing to re-zero between episodes.
- Under 10 ms end to end at 20–30 Hz — responsive enough for dexterous teleoperation, where an inertial glove’s smoothing is the noticeable part.
- 190 g per glove with the battery inside; a full shift is comfortable.
- Immune to the magnetic-field and temperature drift that plagues IMU-based gloves in a room full of motors.
When it is the wrong choice
- Bilateral force control. 20–30 Hz is a capture rate — for force feedback and a wired 100 Hz loop, that is the FFG.
- Full-shift runtime. 3.2 hours is the shortest in the range; plan a second pair or a Type-C power bank for a long day.
- Operators who want nothing on their hand. The exoskeleton is exactly what makes it accurate and exactly what takes getting used to.
Alternatives at a similar level
- Linker MCG (LMCG1-01) — Lightest option, 7 MEMS sensors, about 6 h untethered
- Linker FFG (LFFG1-02/03) — 21 DOF with force feedback and a wired 100 Hz path
- Linker TA (LTA1) — Adds wrist and elbow pose with a chest-mounted 14-DOF arm
Quote this model
Model, quantity and destination is enough to start — we come back with price, availability and the datasheet.
Linker EG (LEG1-02) FAQ
Why does a rigid exoskeleton beat an inertial glove?
Because it measures the angle where the finger actually is, mechanically. An inertial glove integrates rate, so small errors accumulate and the hand has to be re-zeroed. With magnetic encoders on a linkage there is nothing to re-zero, and 0.1° holds for the whole session.
Is the battery replaceable in the field?
The glove charges over USB Type-C with the 500 mAh cell inside. For a long day the practical answer is a second pair rather than a swap — we quote two-glove sets so both hands are covered anyway.
Does it work with the hands and arms?
Yes. Same SDK and ROS packages as the Linker Hand range and the TA teleoperation arm; a glove driving a hand, or a glove driving an arm, is a supported configuration.
How long does it take to ship?
Confirmed per order at quotation, because it depends on quantity and configuration. The quotation carries the date we are working to.
Back to Linkerbot (Linker Hand) · all gloves & teleoperation · need a model that is not listed?