
Full specification
| Parameter | Value |
|---|---|
| Active DOF | 20 |
| Drive | Direct drive in the fingers — no tendon path, no cable wear |
| Weight | 730 g |
| Grip payload | 30 kg |
| Five-finger grip force | 70 N |
| Thumb / four-finger fingertip force | 24 N / 30 N |
| Repeatability | ±0.20 mm |
| Open / close time | 0.8 s |
| Palm envelope | 200 × 92 × 47 mm |
| Sensing | Tactile sensing options across the hand — specify the option with the order |
| Control | CAN / CAN FD · 500 Hz communication |
| Supply | 24–48 V DC · max power 150 W |
| SDK | Open SDK, ROS topics and URDF for Isaac Gym / PyBullet / MuJoCo |
| Best for | Humanoid platforms, research, contact-rich manipulation |
Source: Linkerbot public product pages and the Linker Hand range documentation, cross-checked against the O6 manual for shared-platform details. Figures verified November 2026 — confirm the exact variant against the datasheet issued with your order.
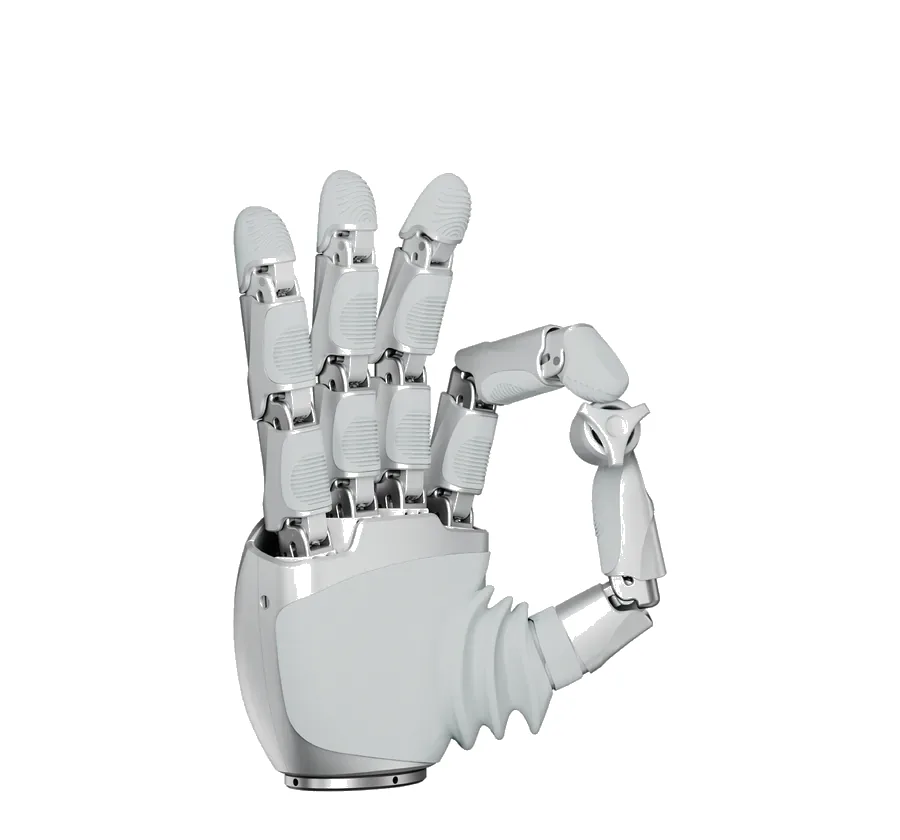
When this is the right choice
- The hand as a sensor. 20 DOF with tactile options across the hand, so contact is measured where it happens rather than inferred from current.
- Best sensed-hand payload-to-weight in the range. 730 g carrying a 30 kg grip.
- One stack across the range. Prototype on an O6 or L20 Lite, move up to O30 without rewriting the integration — same SDK, same ROS topics, same URDF pipeline.
- Direct drive in the fingers. No tendon stretch, no cable fatigue path, and nothing to re-tension after a thousand cycles.
When it is the wrong choice
- Budget-driven pick-and-place. Half the mass and a much lower price at the O6 for a 50 kg grip — if you are not using the sensing, you are paying for it anyway.
- Arms with a small wrist payload budget. 730 g sits at the flange before the object does.
- Assuming every unit ships fully taxel-covered. Tactile sensing is a set of options, not one configuration — the exact option has to be named in the order.
Alternatives at a similar level
- Linker Hand O6 — 6+5 DOF, about 360 g, 50 kg grip, the low-cost work hand
- Linker Hand O20 — 16 DOF direct drive, about 888 g, 20 kg rated / 36 kg peak, self-locking hold
- Linker Hand L30 Pro — 17 active + 4 passive tendon hand with a fingertip tactile array, 15 kg
- Linker Hand L20 — 16 active DOF for in-hand manipulation and data farming
Quote this model
Model, quantity and destination is enough to start — we come back with price, availability and the datasheet.
Linker Hand O30 FAQ
O30 or O20?
O30 is the 20-DOF direct-drive platform hand at 730 g with 30 kg of grip and sensing options across the hand. O20 is 16 DOF direct drive at about 888 g, 20 kg rated and 36 kg peak, with a worm-gear self-locking hold — the better choice for industrial assembly that must hold position.
Does it come with tactile sensing?
There are tactile options across the hand, and which one ships is part of the order. Tell us the task — contact force range, object size, whether you need per-taxel data or just contact detection — and we quote the matching configuration.
Can I prototype on a cheaper hand and move up later?
Yes. The whole range shares one SDK, one set of ROS packages and one URDF pipeline, so code written against an O6 or L20 Lite runs on the O30 with the joint count changed.
How long does it take to ship?
Confirmed per order at quotation. Hands are configured, so the date depends on the sensing option and the quantity; the quotation carries the date we are working to.
Back to Linkerbot (Linker Hand) · all dexterous hands · need a model that is not listed?