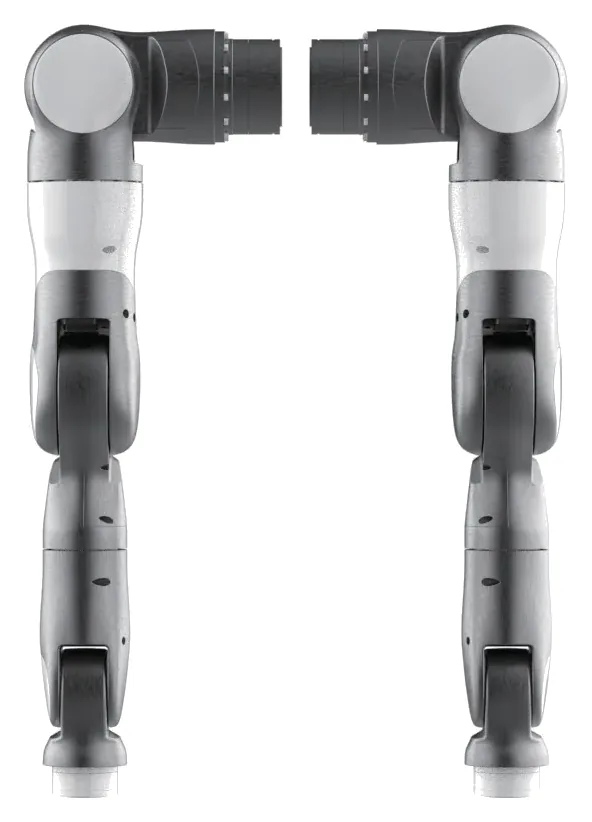
Modules for embodied AI robots
One enquiry, every factory — quoted on one torque scale, shipped as one order, backed by a US-based robotics PhD.
Get a quoteBrowse product linesProduct lines
Four lines, from the axis to the training data — each with the two builds we quote most. Need to compare torque bands? Open the cross-brand joint module comparison.
Harmonic and planetary rotary joints for every axis — arm, leg, waist and wrist. Φ30 to Φ170 frames, 1.65 to 382 N·m rated.
Multi-DOF end-effectors with tactile sensing and force control, from utility hands to research flagships.
Why EmboParts
Direct from the factory is cheaper on paper. Here is what that price does not include — and what you get on top of it at the same price. More about who we are and how we vet these factories →
Technical questions go to our US-based support engineer — a robotics PhD who sizes joints, reads datasheets and debugs EtherCAT — and reach the factory's own engineers in Chinese. Support continues through integration and commissioning, not just until the PO is signed.
We quote and audit these lines year-round. We know which factory is strong in which torque band, whose quality is consistent batch to batch, who ships on schedule and whose "rated" means what. You get a recommendation based on that track record, not a catalog page.
The catalog is where we start, not where we stop. Frameless motors, drivers, torque sensors, brakes, encoders, machined brackets, harnesses and electronics — quoted on the same PO, the same terms and the same shipment as the modules you came for. Full-chain supply, one point of contact.
Good — you should still buy it through us. Same factory price, plus: we verify the configuration and firmware version before it ships, handle export and customs paperwork, take warranty claims in English with an express replacement program, and hold a second source ready if the line has a problem.
Every factory names torque differently — rated at 2000 rpm, allowable average load, start–stop peak, instantaneous max. We normalise them onto a single scale before we quote, so two very different numbers never look like the same one and the comparison you make is real.
Single-unit orders are normal for us. We quote samples and production together, per project, with no minimum-order surprises later — and when you scale, the pricing, lead times and support do not reset because you moved from three units to three hundred.
Beyond the catalog
The lines above are what we publish full tables for. Other module makers, frameless motors and drivers, torque sensors, brakes, encoders, machined brackets, harnesses and electronics — quote them to us and they go on the same purchase order, the same terms and the same shipment. One PO, one point of contact, one consolidated delivery.
Insights
Selection guides, comparison tables and integration notes from the modules we work with every day.
Five signals from the 2026 World Internet Conference Wuzhen Summit: agents that act, identity rails, embodied AI leaving the demo hall, inverted safety doctrine, and open-source brains — each one changes what a hardware BOM has to prove.
2026-11-02A robot joint backlash spec hides three numbers: backlash, repeatability and stiffness. What each one measures, and five questions to ask in writing.
2026-10-29Dexterous hand actuation types compared: linkage, tendon-driven and direct-drive designs, and what each costs you in DOF, control and maintenance.
2026-10-29Bandwidth, cycle time, wiring and failure modes: how to choose between CAN, CAN FD and EtherCAT for a humanoid joint bus without over-specifying.
2026-10-29Continuous, peak and shock torque, the derating factor datasheets leave out, and why a higher reduction ratio can make a joint worse.
2026-10-29From unboxing to go/no-go: the day-by-day checks, pass criteria and scorecard we use to qualify a robot hand before anyone commits to production units.
2026-10-28Backlash, torque density, shock resistance and cost — what actually changes when you pick a harmonic or a planetary reducer for a humanoid joint.
FAQ
Same factory price — plus we verify the configuration and firmware version before it ships, handle export paperwork and customs, take warranty claims in English with an express replacement program, and keep a second source ready in case the line has a problem.
Yes, through commissioning, not just until the PO. Questions go to our US-based robotics PhD and reach the factory’s own engineers in Chinese: joint sizing, datasheets, firmware and EtherCAT debugging, in your working hours.
Yes — prototype quantities are normal for us. We quote per project, samples and production together, with no minimum-order surprises later. When you scale from three units to three hundred, the pricing and support do not reset.
We quote and audit these lines year-round and know each factory’s strengths batch by batch. Every order ships with the configuration verified against your spec, and if a line disappoints we hold alternative sources across our partner factories.
EtherCAT for high axis counts and synchronised motion; CAN or CAN FD in MIT mode for prototypes and lower axis counts. Most lines offer both — tell us your controller and axis count and we recommend the interface that fits.
It depends on the line, and mostly it is fast: the majority of the catalogue ships within about a week from stock, and some configurations are built to order in 4–6 weeks. Stock is not a standing promise — a frame that is on the shelf today can be allocated to another order within days — so we check availability the day you ask and quote a figure per model, not a range. Shipping is worldwide with tracked express, and sample stock in California serves North American buyers. The catalog is where we start, not where we stop — motors, sensors, brakes, brackets and harnesses ride on the same PO and the same shipment.
Contact
Send your build requirements — we reply within one business day with a shortlist and pricing.